Defense-First Ground Autonomy
FOUR MISSIONS.
ONE AUTONOMY CORE.
Start with the ground task. Explore capability, operating scope and field-proven results.
PLATFORM PREPARATION
CLEAR INPUTS. A SHARED PROCESS.
MANUFACTURER PROVIDES
- Command interface / API
- Vehicle control documentation
- Drive type and steering limits
- Dimensions and weight
- Maximum speed
- Safety constraints
TESS SPACE PROVIDES
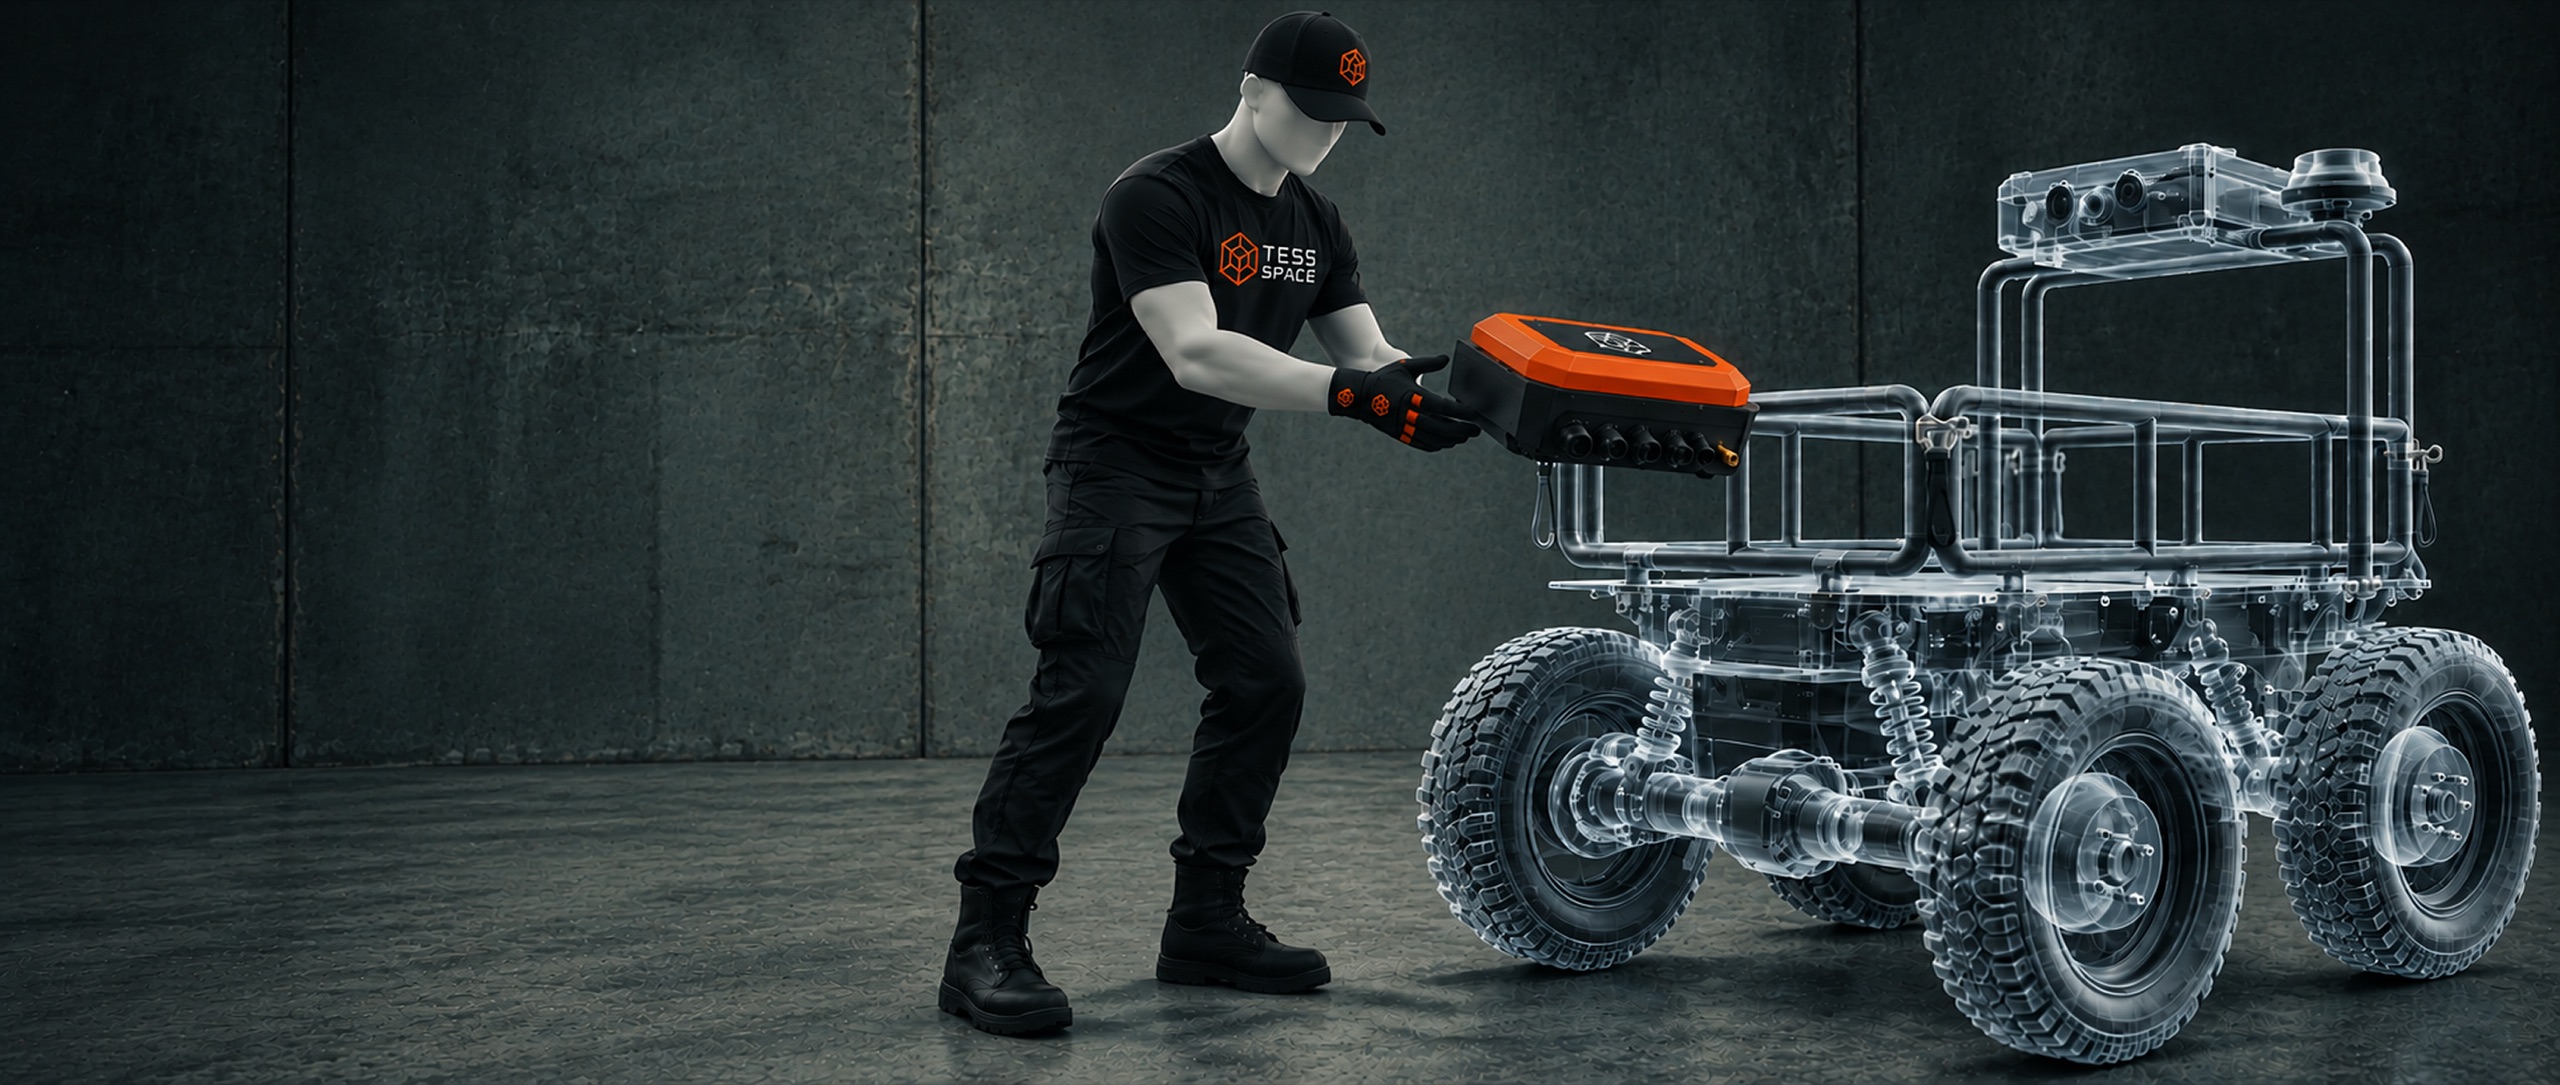
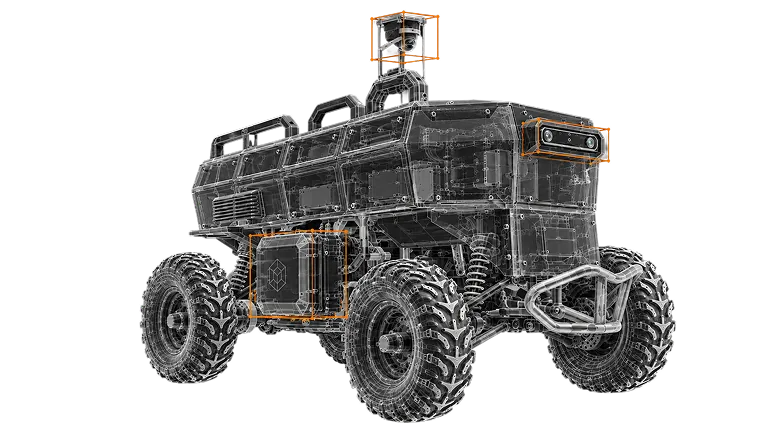
- AI GNC compute
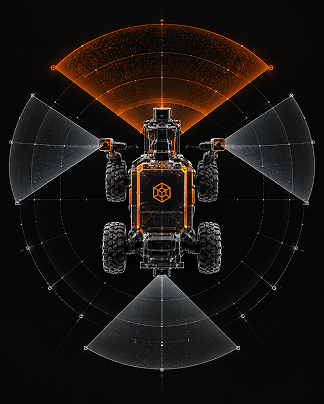
- Cameras and required sensors
- Vehicle-specific adapter layer
- Autonomy-stack configuration
- Calibration
- Validation on the real platform
VEHICLE ONBOARDING
FROM ASSESSMENT TO VALIDATION.
01 →
ASSESS
Analyze vehicle interface and requirements.
02 →
MOUNT
Install AI GNC, sensors and adapter layer.
03 →
CONNECT
Integrate with vehicle command interface.
04 →
CONFIGURE
Configure autonomy stack for your platform.
05 →
CALIBRATE
Calibrate sensors and validate perception.
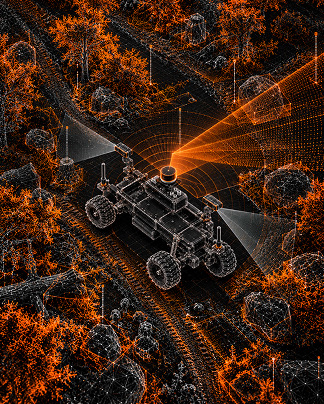
06 →
VALIDATE
Validate on the real vehicle.
Platform compatibility and validation depend on the required command interface and vehicle inputs.
Investor Pathway
Scale the
autonomy layer.
Explore the technology, market opportunity and evidence behind Tess Space. Cross-platform scaling will follow as each platform is validated.