Capabilities

AUTONOMY,
FUNCTION BY
FUNCTION.

Understand each capability, then review its demonstrated scope and current evidence.

CAPABILITY / SCOPE / EVIDENCE

UNDERSTAND THE OPERATING SCOPE.

Off-Road Autonomy

OFF-ROAD AUTONOMY

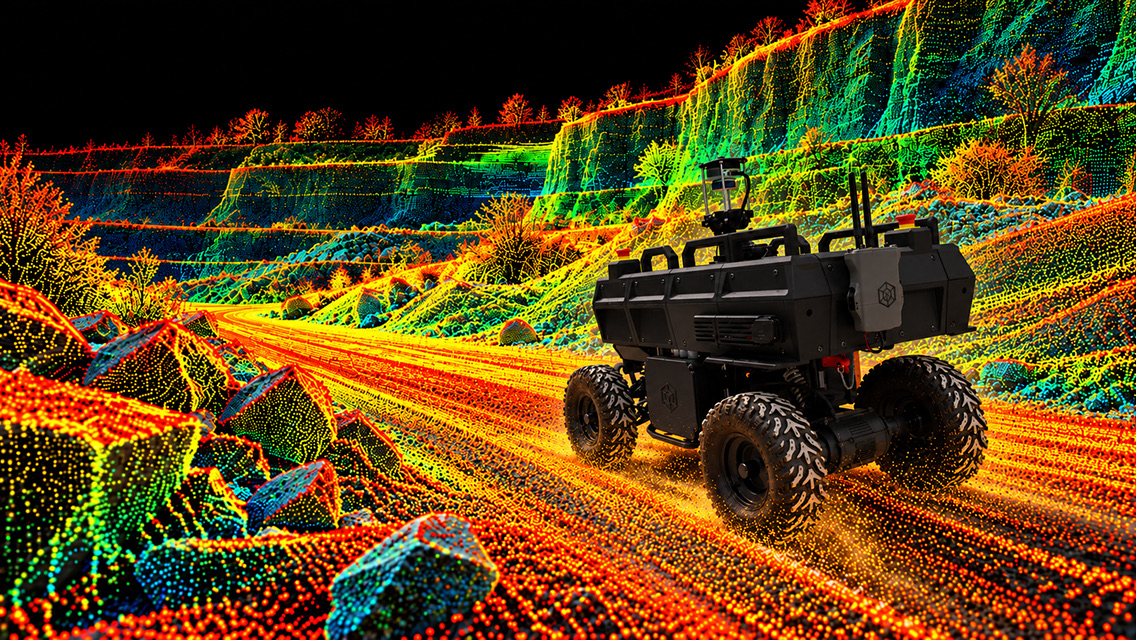
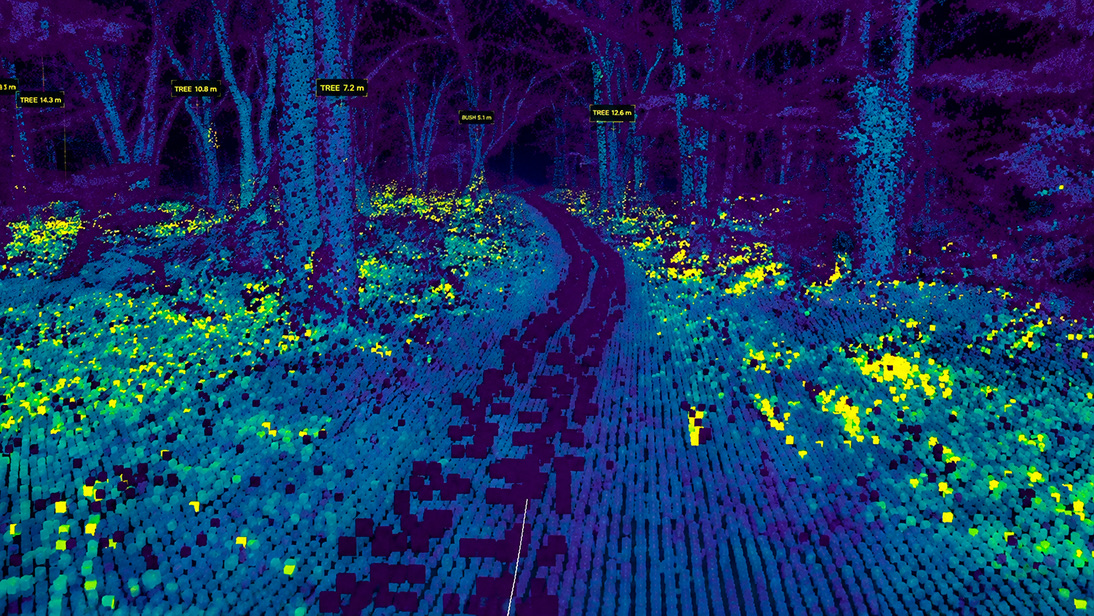
TESS SPACE develops autonomy technology designed to help unmanned ground vehicles navigate challenging off-road terrain. The system combines environmental perception with navigation and motion control to adapt movement to changing ground conditions. Its purpose is to reduce the need for continuous manual steering while supporting mobility across complex environments.
GNSS-Denied Navigation

GNSS-DENIED NAVIGATION

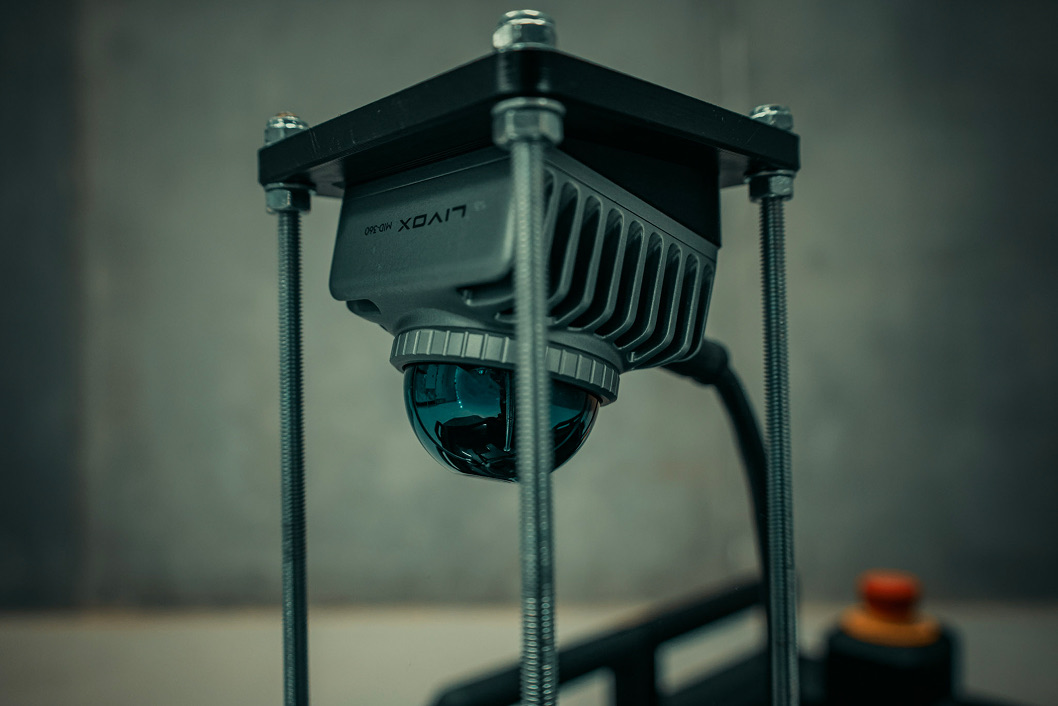
Satellite navigation can become unreliable or unavailable due to interference, obstruction or environmental conditions. TESS SPACE develops navigation capabilities that use onboard sensors and positioning methods to support vehicle operation when GNSS signals are degraded. This approach aims to maintain situational awareness and navigation continuity without relying exclusively on satellite positioning.

Autonomous Navigation

AUTONOMOUS NAVIGATION

Autonomous navigation enables an unmanned ground vehicle to move toward a defined destination with reduced operator input. By combining sensor information, localization and route planning, the system can evaluate its surroundings and determine suitable movement paths. Continuous perception and control support adjustments as terrain conditions and obstacles change.

Autonomous Follow

AUTONOMOUS FOLLOW

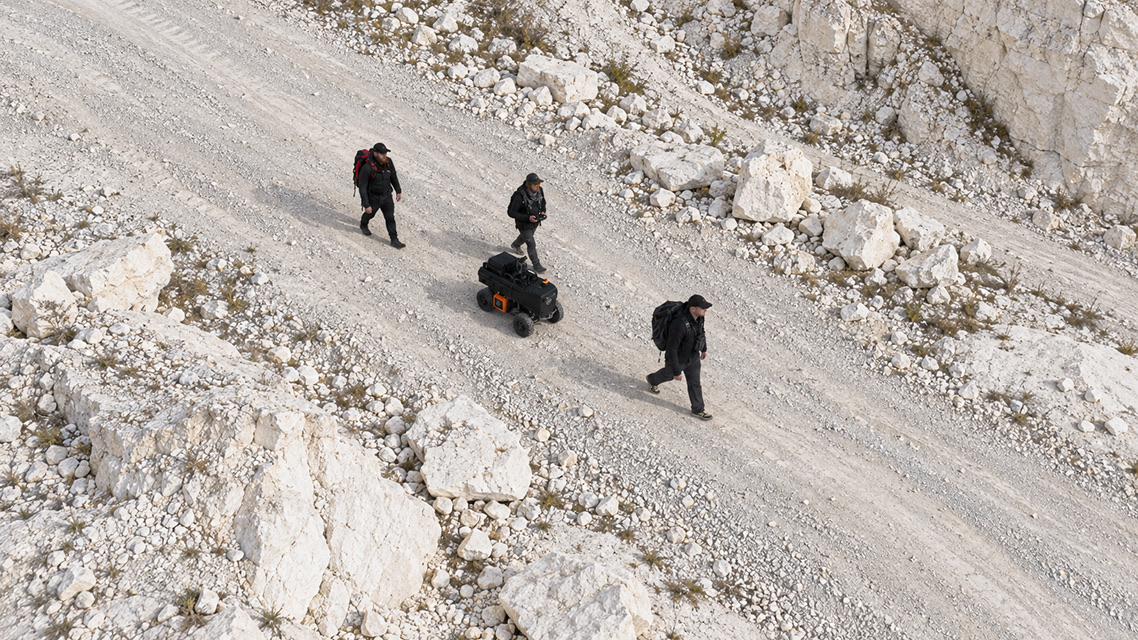
Autonomous Follow is designed to enable an unmanned ground vehicle to follow a designated person or vehicle. Onboard perception and control systems help the UGV track its target while adapting its movement to the surrounding environment. The capability is intended to support personnel during missions involving equipment transport, logistics and mobile assistance.

SEE IT IN ACTION.

Book a live demonstration and explore mission-ready autonomy.